dati |
 bibtex |
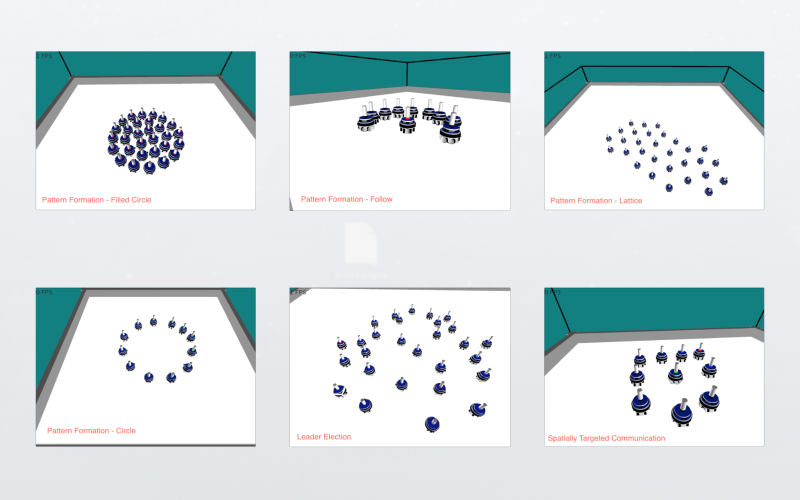
The aim of this project is to study the concepts and the issues of distributed systems applied to the field of robotics. Using ARGoS simulator, we implemented some swarm robotics algorithms from literature about pattern formation and spatially communication. Furthermore we tested the solutions proposed under faulty conditions.